Each task opens with a trained rollout of the solved behaviour. On cartpole,
cheetah, walker, panda, and both Go1 tasks that clip is the strongest PPO
baseline. On hopper it is the best hopping rollout (flat, 8× budget),
because the PPO baseline falls. Then one greedy rollout per variant,
including PPO. The seed is the one with the highest evaluated return for
that variant. Videos loop.
Cartpole
Cheetah
Walker
Hopper
Panda
Go1 flat
Go1 rough
Cartpole
Balance an inverted pole on a cart.
Reference · PPO baseline · seed 2 · return 1000
Flat · seed 1 · return 999
Neural · seed 1 · return 989
NeSy · seed 0 · return 482
Symbolic · seed 2 · return 315
PPO · seed 2 · return 1000
Cheetah
Planar cheetah runs forward as fast as it can.
Reference · PPO baseline · seed 2 · return 879
Flat · seed 21 · return 902
Neural · seed 0 · return 906
NeSy · seed 0 · return 907
Symbolic · seed 1 · return 875
PPO · seed 2 · return 879
Walker
Planar biped walks forward at a target speed.
Reference · PPO baseline · seed 2 · return 995
Flat · seed 5 · return 961
Neural · seed 0 · return 966
NeSy · seed 2 · return 942
Symbolic · seed 1 · return 732
PPO · seed 2 · return 995
Hopper
One-legged hopper hops forward without falling.
Reference · best trained hop · seed 5 · return 648
Flat · 8× budget · seed 5 · return 648
Neural · seed 10 · return 296
NeSy · seed 13 · return 370
Symbolic · seed 1 · return 208
PPO · seed 1 · return 0
Panda
Franka Panda reaches, grasps and lifts a cube.
Reference · PPO baseline · seed 2 · return 1532
Flat · seed 0 · return 1164
Neural · seed 2 · return 456
NeSy · seed 2 · return 458
Symbolic · seed 1 · return 479
PPO · seed 2 · return 1532
Go1 flat
Unitree Go1 tracks a commanded linear and yaw velocity on flat ground.
Reference · PPO baseline · seed 0 · return 17
Flat · seed 4 · return 11
Neural · seed 9 · return 6
NeSy · seed 7 · return 8
Symbolic · seed 2 · return 9
PPO · seed 0 · return 17
Go1 rough
Unitree Go1 tracks a commanded velocity over a heightfield.
Reference · PPO baseline · seed 1 · return 20
Flat · seed 13 · return 6
Neural · seed 17 · return 5
NeSy · seed 2 · return 11
PPO · seed 1 · return 20
RGB observations
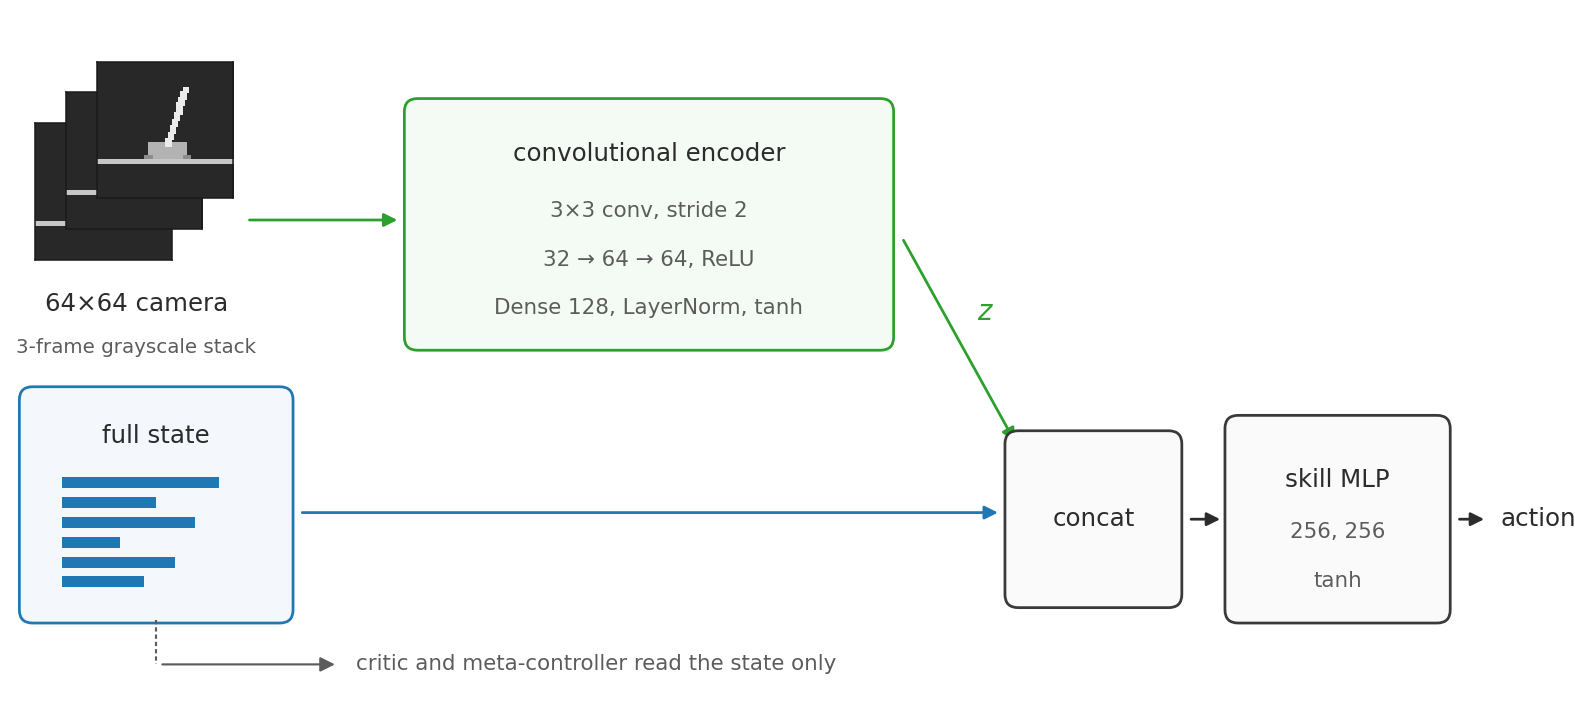
The skill actor encodes the 64×64 three-frame grayscale camera and concatenates that embedding with the full state. The critic and the meta-controller still read the state alone. The clips below are that camera. Side-by-side clips put the state-only rollout on the left and the state-plus-camera rollout on the right.
Cartpole, in-loop camera, seed 0. 64×64 grayscale added to the state.
Cheetah, in-loop camera, seed 0. 64×64 grayscale added to the state.
Walker, in-loop camera, seed 0. 64×64 grayscale added to the state.
Walker, in-loop camera, seed 1. 64×64 grayscale added to the state.
Cartpole, seed 0. State only on the left, state plus camera on the right.
Cheetah, seed 0. State only on the left, state plus camera on the right.
Walker, seed 0. State only on the left, state plus camera on the right.
Walker. State only, seed 0, next to state plus camera, seed 1.